 0
 0
Published: November 2026 | By SoonPu Engineering Team
How to calculate output torque for hypoid gear reducer ratio selections comes down to one formula: T (N·m) = 9550 × P (kW) ÷ n (rpm) × i × η. The 9550 is the constant that converts kilowatts and rpm into newton-meters; the ratio multiplies the motor-side torque; and the efficiency factor is where hypoid geometry quietly beats worm gearing — 94-96% against 70-85% for a single stage. Worked properly, this gear reducer torque formula 9550 with worked examples takes five minutes and prevents the two most common selection mistakes: undersizing on shock loads and ignoring the catalog's continuous rating. The engineering team at Zhejiang SoonPu Electromechanical Co., Ltd. runs through three real cases below.
1. How to calculate output torque for hypoid gear reducer ratio steps?
Compute the motor-side torque first, then multiply by ratio and efficiency — and check the result against the catalog's rated torque, not your target. Three worked examples cover the duty types most buyers bring to us.
• Example 1 — belt conveyor, steady load. A 2.2 kW four-pole motor at 1,420 rpm drives a conveyor through i = 20 with a hypoid stage at η = 0.95. Motor-side torque: 9550 × 2.2 ÷ 1,420 = 14.8 N·m. Output: 14.8 × 20 = 296 N·m before losses, and 296 × 0.95 = 281 N·m delivered. This is the clean case of input torque to output torque conversion with efficiency loss — the loss costs you about 15 N·m, whereas a worm stage at 0.78 would have cost 65 N·m on the same input.
• Example 2 — mixer, high ratio. A 0.75 kW motor at 1,390 rpm through i = 60, η = 0.94: 9550 × 0.75 ÷ 1,390 = 5.15 N·m motor-side, × 60 × 0.94 = 290.6 N·m output. Note the pattern: high ratios multiply torque and cut speed proportionally, so the efficiency factor — not the ratio — decides how much of the theoretical torque survives.
• Example 3 — servo positioning axis. A 0.4 kW servo at 3,000 rpm through i = 10, η = 0.95: 9550 × 0.4 ÷ 3,000 = 1.27 N·m, × 10 × 0.95 = 12.1 N·m continuous. For servo axes the formula gives the continuous value; sizing must still clear acceleration torque, which is where the service factor below matters.
✅ Bottom line: Motor-side torque times ratio times efficiency gives output torque — and at 94-96% efficiency a hypoid stage keeps about 20% more of it than a worm stage of the same ratio.
2. How much margin should you add — and what does the formula miss?
Apply a service factor of 1.0-1.5 by load type, then verify against the catalog's continuous and peak torque ratings — the formula cannot see either. The gear reducer torque formula 9550 with worked examples above gives the duty torque; the margin rules decide whether the unit survives it for years.
• Service factor by load. Uniform loads (belts, fans): 1.0-1.25. Moderate shock (packaging machines, mixers): 1.25-1.4. Heavy shock or frequent starts (crushers, indexers): 1.5 or more. A calculated 281 N·m against a 350 N·m rated unit reads as SF 1.25 — comfortable for packaging duty, marginal for an indexer.
• Continuous vs peak rating. Catalogs list both for a reason: hypoid sets tolerate short overload well, but a duty that sits at peak rating every cycle is a thermal failure in waiting. If your calculated torque sits above the continuous line for more than a few minutes per cycle, step up a frame.
• The swap case. Replacing a worm unit of the same ratio and motor with a hypoid set typically yields about 20-22% more output torque — 281 N·m versus roughly 231 N·m in Example 1 — so existing selections gain margin rather than losing it. Verify the service factor only if your duty includes frequent starts.
• Sanity checks in the plant. Output speed n ÷ i confirms the process speed; back-driving behavior at high ratios differs between geometries, so lifting or holding axes need a brake regardless of the torque margin.
✅ Bottom line: Multiply the formula result by a service factor of 1.0-1.5, then hold it against the catalog's continuous rating — a torque number without a duty-cycle check is half a selection.
FAQ
Q: How to calculate output torque for hypoid gear reducer ratio quickly?
A: T = 9550 × P ÷ n × i × η. Take a 2.2 kW, 1,420 rpm motor at i = 20 and η = 0.95: that is 14.8 × 20 × 0.95 = 281 N·m. Send the four inputs to SoonPu and the factory returns the verified figure with a rated-torque check included.
Q: Does the efficiency factor really change the answer that much?
A: It is the single biggest term after the ratio. The input torque to output torque conversion with efficiency loss in Example 1 kept 281 N·m from 296 N·m theoretical; a worm stage at 0.78 would have delivered only 231 N·m — 50 N·m less from identical hardware upstream.
Q: Can SoonPu verify the selection before I order?
A: Yes. SoonPu is a China manufacturer of hypoid reducers, PMSM motors and drivers offering OEM and custom configurations; send P, n, i and duty cycle and we return a torque verification plus quotation, typically within 24 hours.
Send Your Inputs, Get the Verified Torque
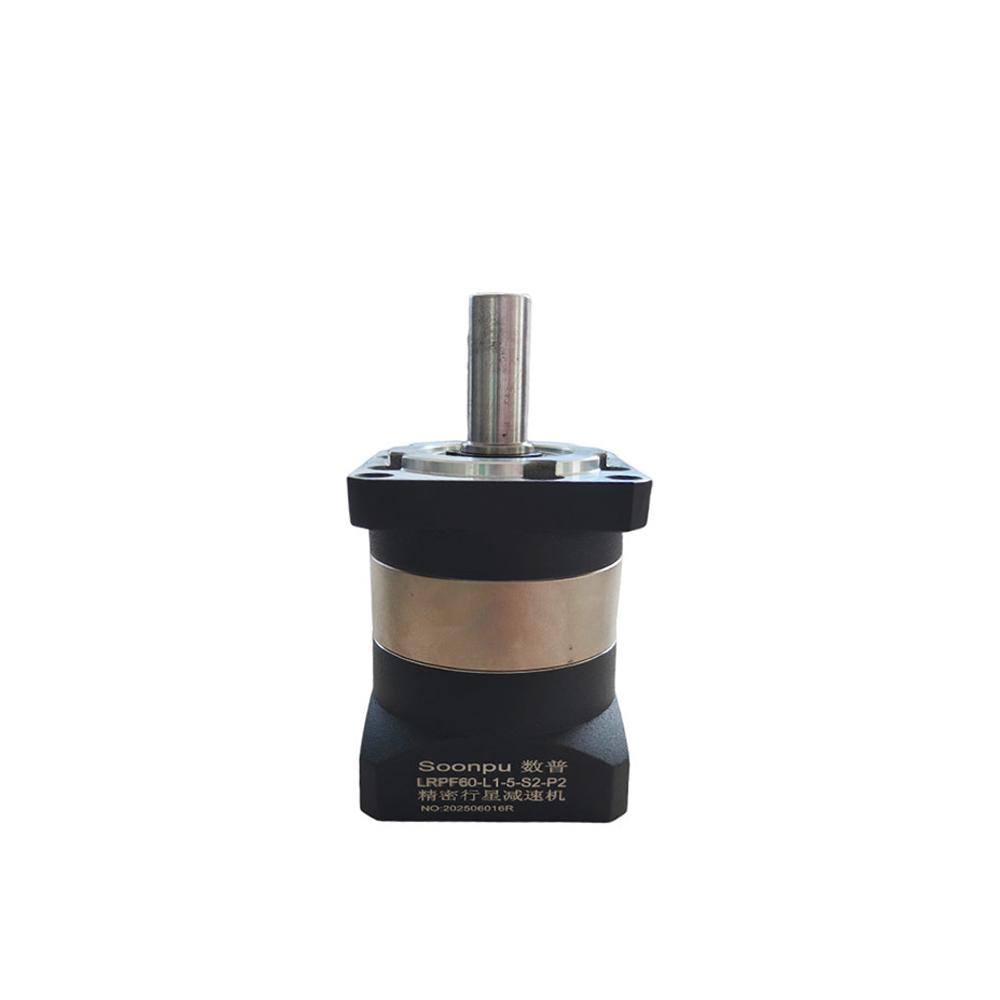
If a datasheet is easier than a formula, send SoonPu your motor power, speed, ratio and load type, and the engineering team at Zhejiang SoonPu Electromechanical Co., Ltd. will run the gear reducer torque formula 9550 with worked examples against your exact duty, confirm the service factor, and return a factory-direct quotation — typically within 24 hours. Contact the factory here. For product data behind the examples, see the quasi-double curved surface reducer series and the PMSM motor range.
www.soonpumotor.com
Zhejiang SoonPu Electromechanical Co., Ltd.


Average Rating